Skip to article frontmatterSkip to article content
Site not loading correctly?

This may be due to an incorrect BASE_URL configuration. See the MyST Documentation for reference.

2.5 Optimality conditions for constrained convex problems

We now turn our attention to convex constrained optimization problems of the form

minimize⁡f0(x)subject to⁡x∈Ω\begin{array}{ll} \minimize& f_0({x})\\ \st & x \in \Omega \end{array}

where f0f_0 is a convex function and Ω\Omega a convex set (by definition of a convex optimization problem). We also assume that f0f_0 is differentiable (i.e., f0∈C1f_0 \in C^1).

One of the key feature of convex optimization problems is that any local optimum is also a global optimum (see this theorem).

First-order characterization of optimal points for convex problems

Proof
  • ⇐{\Leftarrow} Let x⋆∈Ω{x}^\star\in \Omega such that the condition is satisfied. Then by convexity of f0f_0, one has for y∈Ω{y} \in \Omega, f0(y)≥f0(x⋆)+∇f0(x⋆)⊤(y−x⋆)≥f0(x⋆)f_0({y}) \geq f_0({x}^\star) + \nabla f_0({x}^\star)^\top ({y}-{x}^\star) \geq f_0({x}^\star). Thus x⋆{x}^\star is optimal.

  • ⇒{\Rightarrow} Suppose x⋆∈Ω{x}^\star \in \Omega is optimal but the conditions does not hold. There is some y∈Ω{y} \in \Omega for which ∇f0(x⋆)⊤(y−x⋆)<0\nabla f_0({x}^\star)^\top ({y} - {x}^\star) < 0. Consider z(t)=ty+(1−t)x⋆{z}(t) = t {y} + (1-t){x}^\star for t∈[0,1]t \in [0, 1]. Since Ω\Omega is convex, z(t)∈Ω{z}(t) \in \Omega. Moreover, observe that ddtf0(z(t))=∇f0(z(t))⊤(y−x⋆)\frac{\mathrm{d}}{\mathrm{d}t} f_0({z}(t)) = \nabla f_0({z}(t))^\top ({y}-{x}^\star) and thus for t=0t=0 one has ddtf0(z(t))∣t=0=∇f0(x⋆)⊤(y−x⋆)<0\frac{\mathrm{d}}{\mathrm{d}t} f_0({z}(t))\vert_{t=0} = \nabla f_0({x}^\star)^\top ({y}-{x}^\star) < 0. For small positive tt, we thus have f0(z(t))<f0(x⋆)f_0({z}(t)) < f_0({x}^\star) which shows that x⋆{x}^\star is not optimal. Hence we have a contradiction.

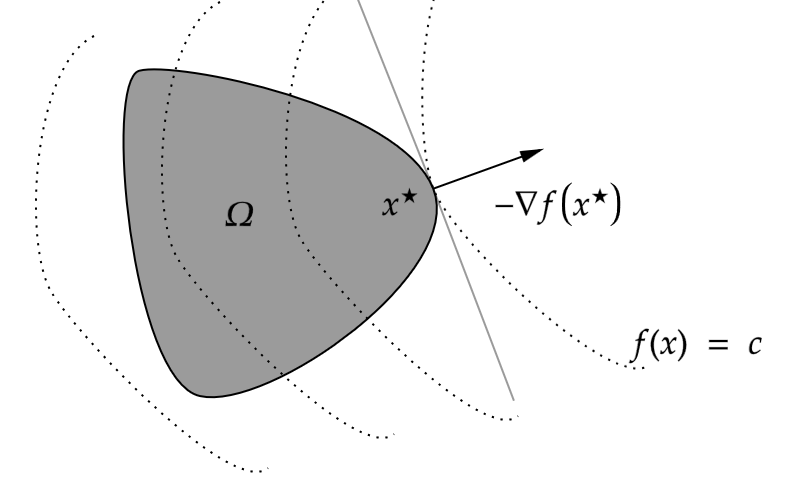
Geometric interpretation

If ∇f0(x⋆)≠0\nabla f_0({x}^\star) \neq 0, the vector −∇f0(x⋆)-\nabla f_0({x}^\star) defines a supporting hyperplane to Ω\Omega at x⋆{x}^\star.

In the context of Theorem 1, letting a=−∇f0(x⋆)a = -\nabla f_0(x^\star) the condition (2) rewrites as a⊤y≤a⊤x⋆{a}^\top {y} \leq {a}^\top {x}^\star for all y∈Ωy \in \Omega. Therefore, {y∣a⊤y=a⊤x⋆}\lbrace {y} \mid {a}^\top {y} = {a}^\top {x}^\star \rbrace is a supporting hyperplane to Ω\Omega at point x⋆x^\star.

Optimality condition illustration

A geometric illustration of the optimality condition for convex problems.
References
  1. Boyd, S. P., & Vandenberghe, L. (2004). Convex optimization. Cambridge University Press.